Skip to content

PR-Web

Press releases worldwide

  • Home
  • Contact
  • Datenschutzerklärung
  • Legal notice

Author: Firma Arnold NextG

The driver shortage is the stress test for public transport

Posted on 7. July 202613. July 2026 by Firma Arnold NextG Posted in General Tagged automation strategy, autonomous mobility, Control Center Integration, driver shortage, fail operational, fleet management, Mobility Infrastructure, mobility-services, operational safety, public transport, public transportation, scalability, Skilled Labour Shortage, System Architecture, Vehicle Control

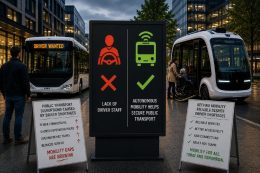
Autonomous mobility is not driven solely by technological innovation. The growing shortage of skilled workers is becoming one of the strongest drivers of new operating models in public transport. This is fundamentally changing the requirements for vehicle architecture, operational organisation […]
Read More

Accessibility is the litmus test for autonomous mobility

Posted on 30. June 202613. July 2026 by Firma Arnold NextG Posted in General Tagged accessibility, Arnold NextG, autonomous mobility, Controllability, drive-by-wire, fail operational, Inclusive mobility, mobility systems, NX NextMotion, precision, public transport, safety architecture, System Architecture, Vehicle Control

  Autonomous mobility will only become relevant to the public when it not only works from a technical point of view, but also enables everyone to use public transport independently and without barriers. That is precisely why accessibility is not […]

Read More

Trust is not the same as authorisation

Posted on 23. June 202613. July 2026 by Firma Arnold NextG Posted in General Tagged Accountability, autonomous mobility, Control Center, Controllability, fail operational, governance, Market Adoption, Operational Stability, Regular Operations, safety architecture, System Architecture, Technical Supervision, transparency, trust, Vehicle Control

Autonomous mobility will not achieve its real breakthrough in public transport through technical approval alone, but through people’s trust in its routine operation. A second factor comes into play once it is legally authorised. However, neither of these is sufficient […]

Read More

Arnold NextG Blogspot: The Wrong KPIs Lead to the Wrong Systems

Posted on 16. June 2026 by Firma Arnold NextG Posted in General Tagged accessibility, autonomous mobility, cost-effectiveness, evaluation, fail operational, fleet management, KPI, Mobility Impact, Operational Stability, public transport, Real-World Operation, scalability, service reliability, System Architecture, Vehicle Control

Many autonomous shuttle projects are considered successful today simply because the vehicles are running. They log test kilometers, navigate defined routes, and reliably demonstrate their driving capabilities. Yet the crucial question often remains unanswered: What does this actually say about […]

Read More

Arnold NextG Blogspot: From Vehicle to Operations

Posted on 9. June 20269. June 2026 by Firma Arnold NextG Posted in General Tagged Arnold NextG, autonomous mobility, Control Center, Controllability, fail operational, Incident Management, Mobility Service, NX NextMotion, Operational Architecture, operational safety, Regular Operation, System Responsibility, Technical Supervision, teleoperation, Vehicle Control

Autonomous mobility is often discussed as a technological issue. Sensors, software, and driving functions are at the center of many debates. However, another dimension is crucial for the successful transition from pilot project to regular operation: the organization of responsibility. […]

Read More

Arnold NextG Blogspot: Scaling Requires System Architecture

Posted on 2. June 2026 by Firma Arnold NextG Posted in General Tagged Arnold NextG, autonomous mobility, Control Layer, drive-by-wire, fail operational, mobility systems, NX NextMotion, platform independence, Regular Operation, safety architecture, Software Defined Vehicle, System Architecture, system control, Vehicle Control, Vehicle Platforms

Autonomous mobility does not scale simply by adding more vehicles or larger fleets. It only scales when vehicle movement remains reproducibly controllable across different platforms, operational areas, and operating states. The discussion about autonomous mobility often focuses on driving functions, […]

Read More

Arnold NextG Blogspot: From Trial Operation to Full-Scale Operation

Posted on 26. May 2026 by Firma Arnold NextG Posted in General Tagged Arnold NextG, autonomous mobility, Autonomous Shuttle Systems, Control Center Integration, drive-by-wire, fail operational, mobility-services, NX NextMotion, Operational Stability, Production Readiness, public transport, Regular Operation, Scalable Mobility, System Architecture, Vehicle Control

Autonomous vehicles are already capable of driving reliably today. The real challenge, however, begins when a pilot project is to be transformed into a permanently stable, economical, and safely controllable regular operation. The discussion about autonomous mobility often focuses on […]

Read More

Arnold NextG Blogspot: Region Instead of Test Bed

Posted on 19. May 2026 by Firma Arnold NextG Posted in General Tagged Arnold NextG, autonomous driving, autonomous mobility, Autonomous Shuttle Systems, connected mobility, drive-by-wire, fail operational, fleet management, NX NextMotion, public transport, Regional Mobility, Scalable Mobilitylable Mobility, System Architecture, Transit Networks, Vehicle Control

Autonomous mobility in public transit rarely fails due to individual vehicles or a lack of technology. The real challenge begins when a local pilot project is to be transformed into a resilient regional mobility system. Following the first successful demonstrations, […]

Read More

Arnold NextG Blogspot: From Pilot Project to Public System

Posted on 12. May 202612. May 2026 by Firma Arnold NextG Posted in General Tagged Arnold NextG, autonomous driving, autonomous mobility, Autonomous Shuttle Systems, brake-by-wire, drive-by-wire, fail operational, NX NextMotion, public transport, Scalable Mobility, Software Defined Vehicle, Steer-by-Wire, System Architecture, Traffic Management, Vehicle Control

Autonomous shuttle projects today demonstrate that vehicles can drive. However, the real challenge begins afterward: How can this be transformed into a resilient, scalable, and safely controllable public system? Autonomous mobility in public transportation is still often viewed on too […]

Read More

Motorsports as a Key to Technological Development: Arnold NextG Makes Its Presence Felt at the Nürburgring

Posted on 5. May 2026 by Firma Arnold NextG Posted in General Tagged Arnold NextG, autonomous driving technology, Dörr Motorsport, endurance racing Germany, future mobility, German tech company, GT3 racing Nürburgring, Keep Fighting Foundation, Michael Schumacher tribute, mobility innovation, motorsport innovation, motorsport sponsorship, Nürburgring 24h race, Schumacher livery, vehicle control technology

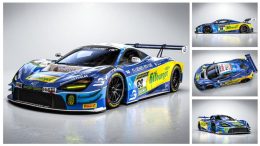
Arnold NextG is participating in the sponsorship of Dörr Motorsport at the 2026 Nürburgring 24-Hour Race. The McLaren 720S GT3 Evo will compete in a design inspired by the legendary Benetton B195, with which Michael Schumacher won his second Formula […]

Read More

Posts navigation

Older posts
Newer posts

Copyright 2016. All rights reserved.


Back To Top
We use cookies to ensure that we give you the best experience on our website. If you continue to use this site we will assume that you are happy with it.